Robot modelling
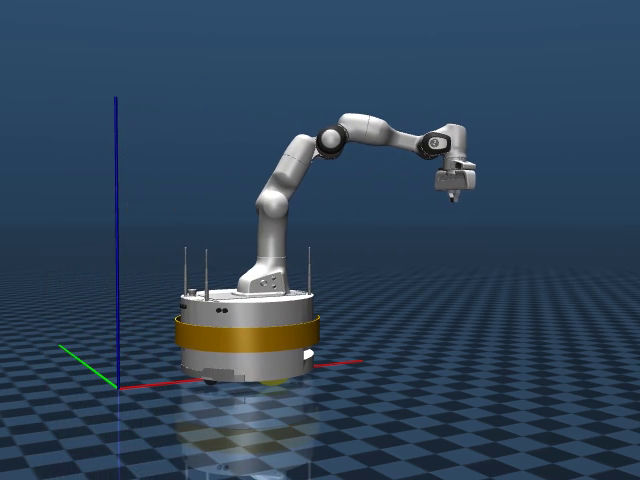
Kinematics, robot and platform models, tools, sensors, coordinate frames, and spatial transformations.
Modelling, simulation and control of robots
Open-source robotics framework
RobotBlockSet (RBS) is a Python framework for modelling robots, generating motion and trajectories, testing algorithms in simulation, and deploying them on real robotic systems. A unified programming interface helps move an application from its initial model to practical execution with minimal changes.
Its modular, object-oriented design makes RBS suitable for robotics research, rapid prototyping, teaching, and industrial applications.
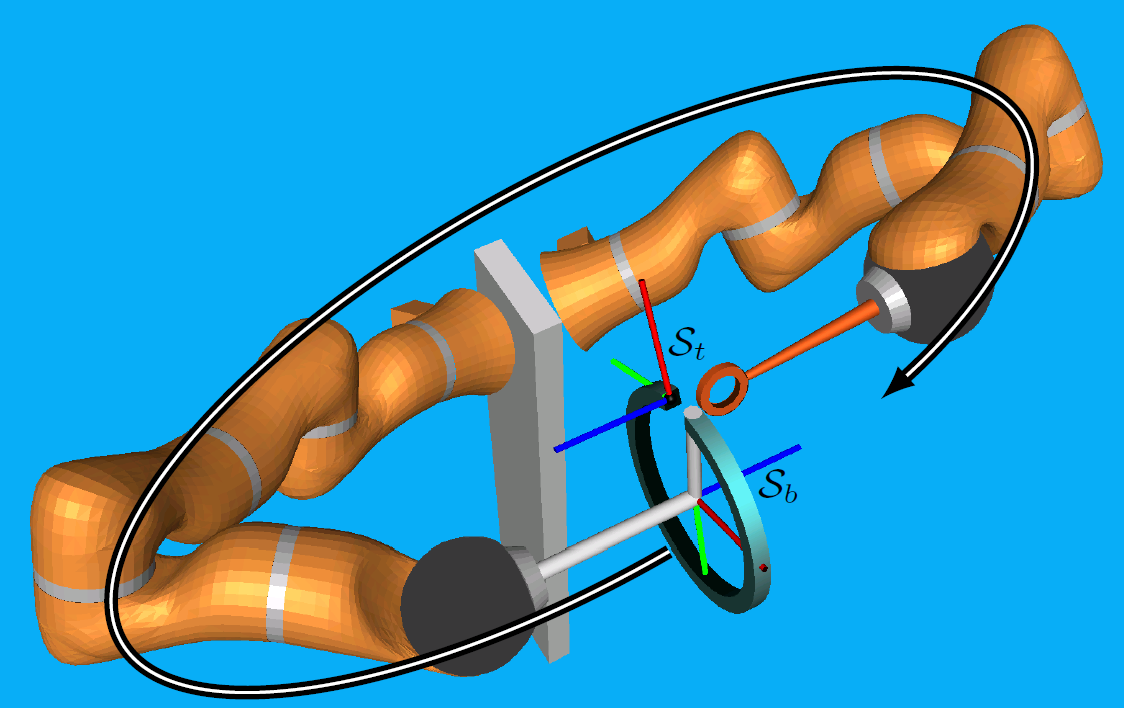
Kinematics, robot and platform models, tools, sensors, coordinate frames, and spatial transformations.
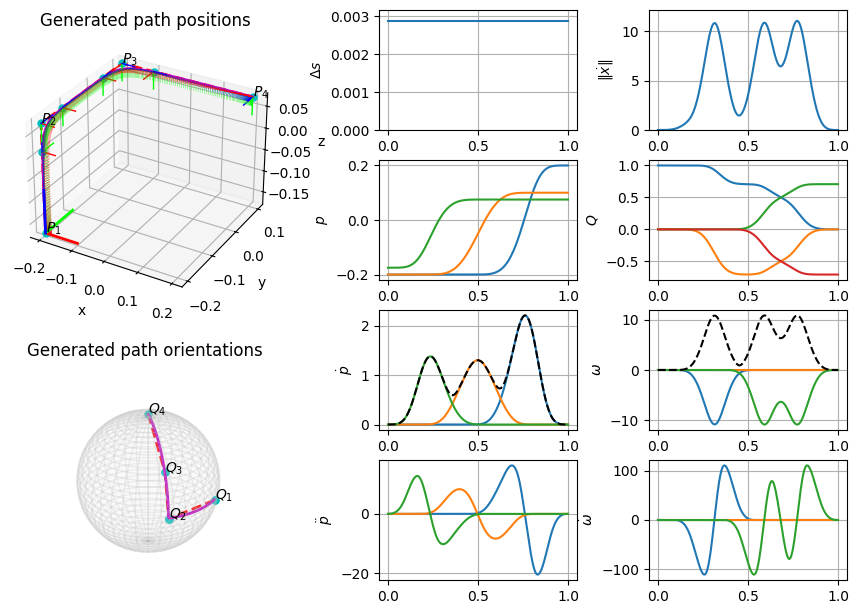
Joint-space and Cartesian paths, interpolation, smooth trajectory profiles, radial basis functions, and time-optimal trajectories.
Collision-free planning through OMPL with collision checking in physics-based simulation environments.
A common high-level interface for simulated systems and physical robots reduces the gap between testing and deployment.
Independent, asynchronous, synchronized, and bimanual operation for coordinated robotic applications.
Trajectory recording, plotting, callbacks, camera support, and tutorial notebooks for developing and evaluating algorithms.
RBS connects to MuJoCo, CoppeliaSim, and Genesis for simulation, and supports middleware and hardware interfaces including ROS/ROS 2, Franka Panda and FR3, Universal Robots through RTDE, and Robotiq grippers. Camera modules and calibration workflows support vision-based robotic applications.
RBS supports Python 3.10 and newer. Install the base package with pip install robotblockset, then use optional extras for robot models, planning, cameras, simulators, or hardware backends. The documentation includes tutorials from spatial operations and motion generation through collision-free planning and real-robot control.